Taking Reinforcement-Learned Motions from Simulation to Real Robots: Bringing Backflips, Handstands, and Wall Climbs to a Quadruped
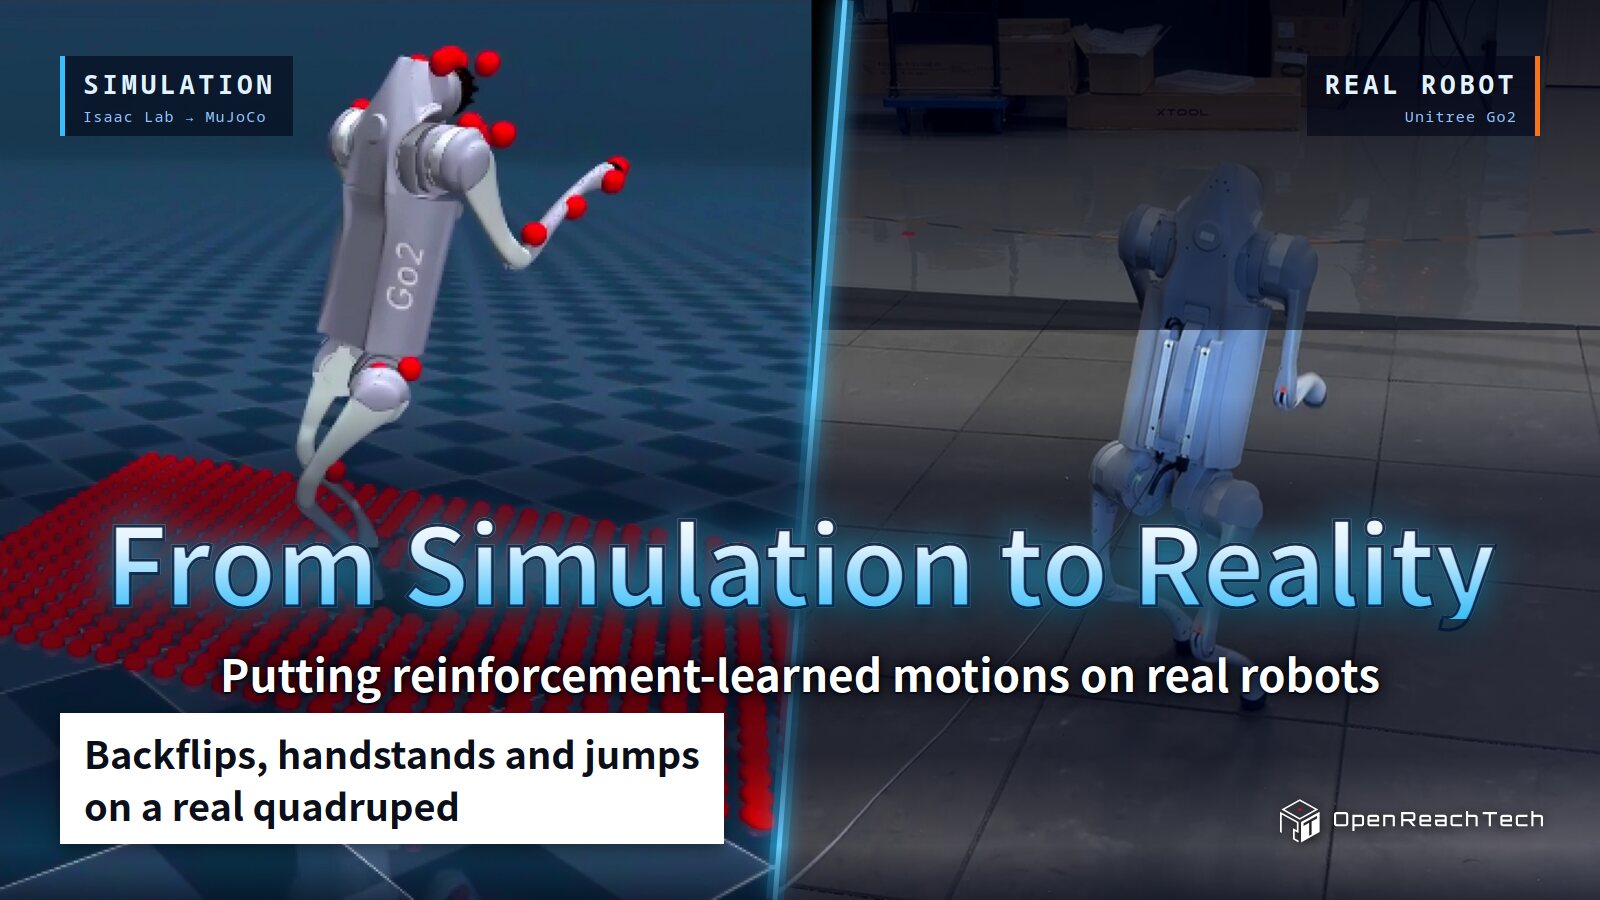
Anything is possible inside a simulation. The hard part is reproducing that same motion on a real robot. We have taken motion policies trained in Isaac Lab and verified in MuJoCo, deployed them to real hardware, and successfully executed galloping, hind-leg standing, backflips, jumps, wall climbing, and self-righting on physical robots. This article walks through our training → sim-to-sim → real-robot deployment pipeline, our battle against "loopholes" in reward design, and the process of closing the sim-to-real gap through actual measurement.
Read case study